I’ve started with the first analyses. A lot of data was collected that will help enormously in making the system more reliable – in particular improving reception quality and shrinking the device. Real competition data simply can’t be simulated that easily. To monitor range and, in the worst case, to recover the model and the GPS device, the current position, speed, battery level and satellite quality were downlinked every few seconds. In the future, this could potentially also allow automated monitoring of no-fly zones.
Today, this data is being made available to everyone in processed form. I prepared a small video for you as well.
Every flight gets a PDF with the results per round. It contains all turn signals including the lap times. On a map you can roughly see where you and your direct competitors flew, and you also get the rough GPS altitude profile of the flights. All of it in very coarse resolution, of course: a position report came in at most every 2–3 seconds, and GPS is not particularly accurate, especially for altitude.
In addition, there is a small time-lapse video for each group where you can watch your flights. Keep in mind that the flight path was interpolated for this, so the aircraft is sometimes not exactly over the line or makes strange movements. The timing may also be slightly off! All information is in the PDF, the video is generated based on that information!
Ich habe mit den ersten Auswertungen begonnen. Es sind viele Daten angefallen, die enorm dabei helfen werden, das System zuverlässiger zu machen und insbesondere die Empfangsqualität zu verbessern und das Gerät zu verkleinern – reale Wettbewerbsdaten lassen sich eben nicht so einfach simulieren. Zur Kontrolle der Reichweite und um im schlimmsten Fall Modell und GPS-Gerät wiederzufinden, wurden alle paar Sekunden die aktuelle Position, Geschwindigkeit, der Akkustand und die Satellitenqualität heruntergesendet. Auch Flugverbotszonen ließen sich damit künftig potenziell automatisiert überwachen.
Diese Daten werden heute in aufbereiteter Form allen zur Verfügung gestellt.
Jeder Flug bekommt ein PDF mit den Ergebnissen je Runde. Darin sind alle Wendesignale inklusive der Rundenzeiten vermerkt. Auf einer Karte könnt ihr grob sehen, wo ihr und eure direkten Konkurrenten geflogen seid. Dazu erhaltet ihr das grobe GPS-Höhenprofil der Flüge. Alles natürlich in sehr grober Auflösung: Es kam maximal alle 2–3 Sekunden eine Positionsmeldung, und gerade bei der Flughöhe ist GPS nicht besonders genau.
Außerdem gibt es von jeder Gruppe noch ein kleines Video, in dem ihr im Zeitraffer eure Flüge ansehen könnt. Bedenkt, dass die Flugbahn dafür interpoliert wurde – daher ist das Flugzeug manchmal nicht genau über der Linie oder macht seltsame Bewegungen. Auch das Timing kann ein wenig abweichen! Alle Informationen sind im PDF, das Video wurde darauf basierend generiert!
Falls ihr (teilgenommene Piloten) die Videos als Datei haben wollt, schreibt mir einfach kurz. Bekommt ihr! If you (participated Pilots) want the Videos as a file, just write me and you get them.
F3B is one of the most demanding and rewarding disciplines in RC soaring — thermal duration, spot landings, and a flat-out speed run that pushes glider and pilot to the limit. But the sport has a staffing problem.
Every aircraft in the distance flight needs two dedicated line judges — one at Base A, one at Base B — each watching for the exact instant a part of the aircraft crosses their line. Run a full round and that’s up to a dozen people tied up on judging duty alone. That’s a heavy ask for organizers — and on a practice day, when nobody’s around to judge, you’re simply flying blind.
F3Cross fixes that. It’s a small, GPS-based electronics system, currently in development, that replaces the line judges entirely — instant, tireless, cheap.
How it works
The system has three parts:
An airborne unit, small and light enough to fly on top of any glider, fixed with a strip of tape, that continuously tracks its own GPS position.
A ground station that receives crossing events and displays them on a computer
A receiver for every pilot that gives turn feedback (acoustic and visual, maybe vibration) plus optional extras like clocks and laps. (This also eliminates the need for one of the pilots helpers who just watches the lights all flight!)
The airborne unit knows exactly where Base A and Base B are. The moment the GPS position shows the aircraft has crossed one of those lines, it fires an event and sends it wirelessly to the ground — almost instantly, with none of the reaction-time lag or subjectivity a human judge has. It works just as well solo on a practice day as it does with a full contest.
For reliability, every crossing is sent over two independent radio links at once. If one link drops out, the other one usually still gets through, so a single crossing is less likely to be lost to bad luck on the radio.
Proven in the field
This isn’t just a bench project. In testing — including flights with an electric F3B — the system has tracked aircraft up to 660 m in altitude and out to nearly 700 m in distance, and kept catching crossings.
At the F3B competition site in Büllingen, Belgium, the setup was flown with two aircraft in the air at once. The pilots and helpers — Markus, Thilo, and Steffen — were happy with the accuracy, the low delay, and the handling. They thought it might even be usable in speed as well, but that is no priority for now! A few things still need work, like the antennas, good ergonomics, volume of the beepers, but as a first run it held up very well.
What’s next
I’ve been testing this in the field for only a short time yet, but it is already working well. If this gets even one more club running contests with a smaller crew, or gets one more pilot out practicing on a day they’d otherwise have skipped, it’s done its job. Next up: the next integrated PCB edition, with an even smaller footprint and higher reliability and usability. Testing will continue, and hopefully it’s ready to deploy at F3B Söhl. After that competition I want to make the hardware and software publicly available.
The picture show the flown prototypes. Please be aware that this were only prototypes with hardware i had lying around anyway. The next version will be much smaller and better to mount onto the aircraft! (More technical details below, only for the interested!)
Update 1: To clarify, all hardware will be provided by the competition,. As a pilot you do NOT have to buy anything! Just mount the module before your flight and fly…
Follow along here on the blog for updates. Fly more, judge less.
The details, for the curious
A quick note on scope first: F3Cross is not designed to judge the speed task in competition, for now. At the speeds and g-loads of a speed run, the precision demands go up sharply — that’s a harder problem, and one I’d rather solve properly than rush. Today it’s built for distance-task line crossings and for training, where it’s already a clear upgrade over the realistic alternative: nobody watching at all.
Design requirements
Cheap and easy to build and repair. Anyone should be able to afford one.
Quick to reprogram for the contest director. Setting up a new course or base position shouldn’t take longer than briefing the pilots.
Tamperproof, to a degree. Each crossing signal carries a small amount of encryption so the ground station can verify it’s genuine, not spoofed.
Self-detects a missed signal. If a crossing doesn’t come through, the system knows it — so the contest director can decide on a reflight immediately, instead of arguing about it after the round. This is comparable to a judge that mixed up the aircraft.
Built from off-the-shelf parts. The goal is a small, integrated form factor, but anyone should still be able to build a slightly bigger version themselves with nothing more than a soldering iron. (The smaller PCB version will require SMD soldering.)
The hardware
The whole thing is built from cheap, widely available hobbyist electronics — a small ESP32-based microcontroller board, a LORA transceiver, and a GPS module. Right now it uses a u-blox M8 GPS, which already gives more than enough precision and update rate to catch a crossing cleanly. A u-blox M10 upgrade is coming soon, bumping the position update rate to 25 Hz and adding support for all satellite constellations (not just GPS) for even better accuracy.
Planned final Hardware
ESP32-S3 for high processing power and background radio operation. ESPNOW-LR protocol for low frequency position updates and fast turn signal communication
Semtech SX1262 LORA module 868MHz for long range, reliable but slower turn signal communication
ublox M10Q GPS chip with a simple wire antenna to allow omnidirectional reception
Antennas are still in testing. The small one might have occasional blocking in extremely bad and distant flight situations, but there is still a lot to be improved in software! The big antenna was already flown over 650m high with the carbon fuselage in the worst position and still got the signal. For now, the smaller antenna will have priority
I will try to make the final prototype CG neutral, resulting in a slightly longer device, but not requiring counterweights in the nose of the aircraft. The antennas will be behind the wing to not reduce yaw damping and not be blocked by the wing’s CFRP.
Caveats and testing / How it compares to a human judge
A human judge isn’t perfect, and neither is this. As speeds and g-loads go up, both approaches get less accurate. To keep that error honest rather than hidden, I want to describe some of the caveats that have already been discovered or are still unknown risks.
The system only interpolates once between GPS fixes (using the last position and speed), and insists on a good fix before it will call a crossing at all — it would rather stay quiet than guess.
Right at the base, a human helper still has a slight edge. Further out, a human judge loses accuracy fast — sighting-line thickness, a vibrating line, a small aircraft far away — none of which affects GPS.
There is also no deviation in the parallelity of the base lines as with a current competition setup (although earth’s curvature is not accounted for 😉 ).
If the radio signal drops or the GPS signal is not fixed, that can create a situation a human judge would never have missed. On the other hand, the system can never lose sight of the aircraft the way a human eye can. All pilots fly the same hardware and will experience mostly identical issues under similar conditions.
Because a missed signal due to a lost radio contact is detectable, the moment the connection comes back, that pilot simply gets offered a reflight — no dispute, no guesswork.
The worst case is the antenna being fully shielded by the aircraft’s own carbon fibre structure, combined with long range. (flying straight directly above the ground station) There are already ideas for making that shielding practically impossible using multiple ground stations — but for now, the plan is: keep it simple.
GPS drift is still an open question. Quick drifts within a few seconds will be impossible to correct without expensive and much more complicated RTK/DGPS setups. But if it is only a slow drift over minutes, a single GPS reference station at a base could send low frequency correction signals to the aircraft.
Loss of GPS is more difficult to detect, but during the test we never had this problem in regular flight states (not inverted, no rolls, no extreme accelerations).
A standalone version that doesn’t need a PC at the ground station is easily doable, and will follow — but only once the current competition setup is proven and running well.
Free to build
F3Cross will be free to build for your own flying. The exact license is still being worked out, but the plan is: free for personal and competition use, changes and improvements are welcome as long as the original project is credited, and no commercial use without approval. Once it’s ready, the full design — hardware and firmware — will be published so anyone, anywhere, can put one together and start flying with fewer people on the field. If you’d rather not source parts and solder it up yourself, I’m looking at organizing a bulk parts order and possibly pre-soldering for the community for a small fee to cover expenses.
Follow along here on the blog for updates. Fly more, judge less.
German version: (maschinell übersetzt und leicht überarbeitet)
F3B ist eine der anspruchsvollsten und interessantesten Disziplinen im RC-Segelflug — Thermikdauerflug, Ziellandungen und ein Speedflug am Limit, der Modell und Pilot alles abverlangt. Aber der Sport hat ein Personalproblem.
Jedes Modell im Streckenflug braucht zwei eigene Wenderichter — einen an Basis A, einen an Basis B — die jeweils auf den exakten Moment achten, in dem ein Teil des Modells ihre Linie überquert. Für eine komplette Runde sind das bis zu einem Dutzend Leute, die allein damit beschäftigt sind. Das ist viel verlangt von den Veranstaltern — und an einem Trainingstag, an dem niemand da ist, fliegt man schlicht blind.
F3Cross löst das. Es ist ein kleines, GPS-basiertes elektronisches System, aktuell in Entwicklung, das die Wenderichter komplett ersetzt — sofort, unermüdlich, günstig.
Wie es funktioniert
Das System besteht aus drei Teilen:
Eine Flugeinheit, klein und leicht genug, um mit einem Streifen Klebeband auf jedem Modell mitzufliegen, die kontinuierlich ihre eigene GPS-Position verfolgt.
Eine Bodenstation, die die Wendeereignisse empfängt und auf einem Computer anzeigt.
Ein Empfänger für jeden Piloten, der Wende-Feedback gibt (akustisch und visuell, vielleicht per Vibration) plus optionale Extras wie Uhren und Rundenzähler. (Damit entfällt auch einer der Helfer, der den ganzen Flug lang nur auf die Lampen schaut!)
Die Bordeinheit kennt die genaue Lage von Basis A und Basis B. In dem Moment, in dem die GPS-Position zeigt, dass das Modell eine dieser Linien überquert hat, löst sie ein Ereignis aus und sendet es drahtlos zum Boden — praktisch verzögerungsfrei, ohne die Reaktionszeit und Subjektivität eines menschlichen Richters. Es funktioniert allein am Trainingstag genauso gut wie bei einem vollen Wettbewerb.
Für die Zuverlässigkeit wird jede Wende gleichzeitig über zwei unabhängige Funkstrecken gesendet. Fällt eine Strecke aus, kommt die andere meist trotzdem durch — eine einzelne Wende geht so seltener verloren.
Im Feld erprobt
Das ist kein reines Laborprojekt. In Tests — darunter Flüge mit einem elektrischen F3B — hat das System Modelle bis in 660 m Höhe und 700 m Entfernung verfolgt und dabei weiter Wenden erfasst.
Auf dem F3B-Wettbewerbsgelände in Büllingen, Belgien, wurde mit zwei Modellen gleichzeitig in der Luft geflogen. Die Piloten und Helfer — Markus, Thilo und Steffen — waren zufrieden mit der Genauigkeit, der geringen Verzögerung und dem Handling. Sie hielten es sogar für möglicherweise brauchbar im Speed, aber das hat vorerst keine Priorität! Ein paar Dinge müssen noch verbessert werden, etwa die Antennen, eine gute Befestigung und die Lautstärke der Piepser, aber für einen ersten Durchlauf hat es sich sehr gut geschlagen.
Wie es weitergeht
Ich teste das System erst seit kurzer Zeit, aber es funktioniert bereits gut. Wenn dadurch auch nur ein Verein mehr seine Wettbewerbe mit kleiner Crew durchführen kann, oder auch nur ein Pilot mehr zum Üben rausgeht, wenn er sonst zu Hause geblieben wäre, hat es seinen Zweck erfüllt. Die nächsten Schritte: die nächste integrierte Platinenversion, mit noch kleinerem Formfaktor und höherer Zuverlässigkeit und besserer Bedienbarkeit. Die Tests gehen weiter, und hoffentlich ist es rechtzeitig zum F3B Wettbewerb Söhl einsatzbereit. Nach diesem Wettbewerb möchte ich Hardware und Software öffentlich zugänglich machen.
Die Bilder zeigen die geflogenen Prototypen. Bitte beachtet, dass das nur Prototypen aus Teilen waren, die ich ohnehin herumliegen hatte. Die nächste Version wird deutlich kleiner und besser am Modell zu montieren sein!
(Weitere technische Details unten, nur für Interessierte!)
Folgt hier im Blog für Updates. Fly more, judge less.
Die Details, für die Neugierigen
Zunächst eine kurze Anmerkung zum Umfang: F3Cross ist vorerst nicht dafür ausgelegt, die Speedaufgabe im Wettbewerb zu bewerten. Bei den Geschwindigkeiten und g-Belastungen eines Speedflugs steigen die Präzisionsanforderungen stark an — das ist ein schwierigeres Problem, und eines, das ich lieber sauber lösen als überstürzen möchte. Erstmal ist es für die Wenden der Streckenaufgabe und fürs Training gebaut, wo es der realistischen Alternative — nämlich niemandem, der zuschaut — schon jetzt klar überlegen ist.
Designanforderungen
Günstig und einfach zu bauen und zu reparieren. Jeder sollte sich eines leisten können.
Schnell umzuprogrammieren für den Wettbewerbsleiter. Einen neuen Kurs oder eine neue Basisposition einzurichten, sollte nicht länger dauern als das Briefing der Piloten.
Bis zu einem gewissen Grad manipulationssicher. Jedes Wendesignal beinhaltet eine kleine Verschlüsselung, damit die Bodenstation überprüfen kann, dass es echt und nicht gefälscht ist.
Erkennt fehlende Signale selbst. Kommt eine Wende nicht durch, weiß das System davon — der Wettbewerbsleiter kann also sofort über einen Wiederholungsflug entscheiden, statt hinterher über die Runde zu streiten. Das ist vergleichbar mit einem Linienrichter, der die Modelle verwechselt hat.
Aus Standardbauteilen aufgebaut. Das Ziel ist ein kleiner, integrierter Formfaktor, aber jeder soll trotzdem eine etwas größere Version mit nichts weiter als einem Lötkolben selbst bauen können. (Die kleinere Platinenversion erfordert SMD-Löten.)
Die Hardware
Das Ganze besteht aus günstiger, breit verfügbarer Hobbyelektronik — einem kleinen ESP32-basierten Mikrocontrollerboard, einem LoRa-Transceiver und einem GPS-Modul. Aktuell kommt ein u-blox M8 GPS zum Einsatz, das schon mehr als genug Präzision und Updaterate bietet, um eine Wende sauber zu erfassen. Ein Upgrade auf das u-blox M10 folgt bald und hebt die Positions-Updaterate auf bis zu 25 Hz an, bei gleichzeitiger Unterstützung für alle Satellitenkonstellationen (nicht nur GPS) für noch bessere Genauigkeit.
Geplante finale Hardware
ESP32-S3 für hohe Rechenleistung und Funkbetrieb auf dem zweiten Rechencore. ESPNOW-LR-Protokoll für niederfrequente Positionsupdates und schnelle Übertragung der Wendesignale.
Semtech SX1262 LoRa-Modul 868 MHz für große Reichweite und zuverlässige, aber langsamere Übertragung der Wendesignale.
u-blox M10Q GPS-Chip mit einer einfachen Drahtantenne für omnidirektionalen Empfang.
Die Antennen sind noch in der Erprobung. Die kleine 868MHz könnte in extrem ungünstigen und weit entfernten Flugsituationen gelegentlich abgeschattet werden, aber softwareseitig lässt sich hier noch einiges verbessern! Die große Antenne wurde bereits über 650 m hoch geflogen, mit dem Kohlefaserrumpf in der ungünstigsten Lage, und bekam trotzdem noch das Signal. Vorerst hat die kleinere Antenne aber Priorität.
Ich werde versuchen, den finalen Prototyp schwerpunktneutral zu gestalten, was ihn etwas länger macht, dafür aber keine Trimmgewichte im Rumpf erfordert. Die Antennen werden hinter der Fläche sitzen, um die Gierdämpfung nicht zu verringern und nicht vom CFK der Fläche abgeschattet zu werden.
Einschränkungen und Tests / Der Vergleich mit einem menschlichen Linienrichter
Ein menschlicher Richter ist nicht perfekt, und dieses System ist es auch nicht. Mit steigenden Geschwindigkeiten und g-Belastungen werden beide Ansätze ungenauer. Damit dieser Fehler offen kommuniziert ist und nicht versteckt wird, möchte ich einige der Einschränkungen beschreiben, die bereits entdeckt wurden und noch unbekannte Risiken darstellen.
Das System interpoliert zwischen zwei GPS-Fixes nur einmal (aus letzter Position und Geschwindigkeit) und besteht auf einem guten Fix, bevor es überhaupt eine Wende meldet — es schweigt lieber, als zu raten.
Direkt an der Basis hat ein menschlicher Helfer noch einen Vorteil. Weiter draußen verliert ein menschlicher Richter schnell an Genauigkeit — Dicke der Peillinie, eine vibrierende Schnur, ein kleines Modell weit weg — nichts davon beeinflusst GPS. Es gibt außerdem keine Abweichung in der Parallelität der Basislinien wie bei einem heutigen Wettbewerbsaufbau (auch wenn die Erdkrümmung aktuell nicht berücksichtigt wird 😉 ).
Wenn das Funksignal abreißt oder das GPS keinen Fix hat, kann ein Fehler passieren, der einem menschlicher Richter nie passiert wäre. Andererseits kann das System das Modell nie so aus den Augen verlieren, wie es einem menschlichen Auge passiert. Alle Piloten fliegen dieselbe Hardware und werden unter ähnlichen Bedingungen weitgehend identische Probleme erleben.
Weil ein fehlendes Signal durch verlorenen Funkkontakt erkennbar ist, bekommt der betreffende Pilot in dem Moment, in dem die Verbindung zurückkommt, einfach einen Wiederholungsflug angeboten — keine Diskussioinen, kein Rätselraten.
Der schlimmste Fall ist die vollständige Abschattung der Antenne durch die Kohlefaserstruktur des eigenen Modells in Kombination mit großer Entfernung (also der Flug direkt senkrecht über die Bodenstation). Es gibt bereits Ideen, diese Abschattung mit mehreren Bodenstationen praktisch unmöglich zu machen — aber vorerst lautet der Plan: einfach halten.
Probleme beim GPS-Empfang sind nur schwer zu analysieren. In normalen Flugzuständen (kein Rückenflug, keine ROllen, normale Wendenbeschleunigungen) wurde jedoch nie ein Problem festgestellt.
GPS-Drift ist noch eine offene Frage. Schnelle Drifts innerhalb weniger Sekunden werden ohne teure und deutlich kompliziertere RTK/DGPS-Aufbauten nicht zu korrigieren sein. Handelt es sich aber nur um eine langsame Drift über Minuten, könnte eine einzelne GPS-Referenzstation an einer Basis niederfrequente Korrektursignale ans Modell senden.
Eine eigenständige Version, die an der Bodenstation keinen PC braucht (fürs Training), ist problemlos machbar und wird folgen — aber erst, wenn der aktuelle Wettbewerbsaufbau erprobt ist und zuverlässig läuft.
Frei nachbaubar
F3Cross wird für den eigenen Flugbetrieb frei nachbaubar sein. Die genaue Lizenz wird noch ausgearbeitet, aber der Plan ist: frei für den privaten Gebrauch und für Wettbewerbe. Änderungen und Verbesserungen sind willkommen, solange das Originalprojekt genannt wird. Keine kommerzielle Nutzung ohne Genehmigung. Sobald es fertig ist, wird das komplette Design — Hardware und Software— veröffentlicht, damit jeder, überall, sich eines zusammenbauen und mit weniger Leuten auf dem Platz fliegen kann. Wer Teile nicht selbst beschaffen und löten möchte: Ich prüfe, ob sich eine Sammelbestellung organisieren lässt, eventuell mit Löten der SMD teilew für die Community gegen eine kleine Gebühr zur Deckung der Unkosten.
Update 1: Zum Klarstellen: die Hardware wird vom Wettbewerb zur verfügung gestellt. Die Piloten müssen nichts dafür vorher kaufen! Einfach das Modul vor dem Streckenflug am Flieger befestigen und Spaß haben…
Folgt hier im Blog für Updates. Fly more, judge less.
Update: Unfortunately, this type of resistor is probably banned starting 2027. I do not like this decision.
I’d like to shed light on why these resistors were developed, how they work, and what benefits they bring. This report outlines the challenges that led to the idea, the development process, the results of extensive testing, and why I believe these resistors are a practical and affordable option for many pilots.
How It Started
The work began in 2020–2021, when competitions were suspended due to COVID-19. I had just finished my studies and finally had the freedom to attend more competitions, use my time more flexible to go for training and experiment with the hardware. I focused on finding the best setup for my winches.
In 2021, the limitation on cold crank current for batteries was lifted. This change made sealed AGM batteries possible: they are safer for transport, storage, and use in competition. With my small car and difficult transportation, I was eager to make a quick switch and welcomed the change. Additionally, I wanted to explore whether larger batteries would provide an advantage under high-current launches, so I purchased a large 105Ah Varta AGM battery. (Later, i would regret this heavy battery and I am not using it any more due to the impacts of its weight)
In early tests with an electronic load, the battery performed extremely well. But when I connected it to my winches, problems appeared:
Resistance too low: My stainless-steel resistor setup was no longer sufficient.
Bulky construction: To reach higher resistance, I had to chain two or three long resistors together.
Safety risk: Large exposed resistors made accidental short circuits more likely.
Heat: Minutes after simulated launches, resistors exceeded 200 °C. Heat transferred through the screws and clamps, causing painful burns even minutes later. (Guess, how i know 😉)
Clearly, stainless steel was not an ideal solution.
Sidenote (unrelated to these resistors):
Additionally, the better battery is no longer almost compensating the change in resistance of the motor if temperature changes. This lead to increased safety margins that i use myself. At the WC2023 we had a close measurement, even though we adjusted to min 23.7mOhm. Since i was not able to measure and adjust the winches as often at this years WC, we set up over 24mOhms at worst-case cold conditions just to be safe. The official measurements with over 25mOhms reflect that decision. It also helps with variating resistance of the motor, depending on the rotation position. But that is going into some other rabit hole…
Searching for a Better Material
I needed a resistor that was:
Smaller and easier to handle
Stable under high current
Affordable and easy to build
Kanthal was unavailable, and even if it were, it wouldn’t have solved the core issues. Stainless steel also had another disadvantage: its resistance increased with temperature.
My research in Wikipedia quickly pointed me toward carbon:
High electrical resistance
Low thermal conductivity (less heat transferred to clamps)
Inexpensive and easy to source
Negative temperature coefficient as a benefit
At first, I doubted carbon could carry the required currents. But our winch motors already rely on carbon brushes, so I decided to test it.
Prototyping and Early Tests
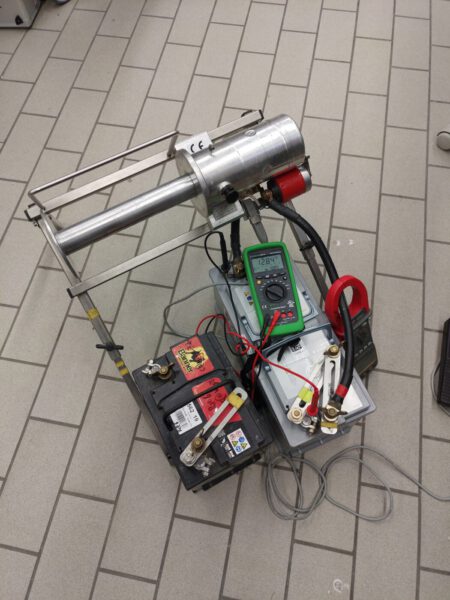
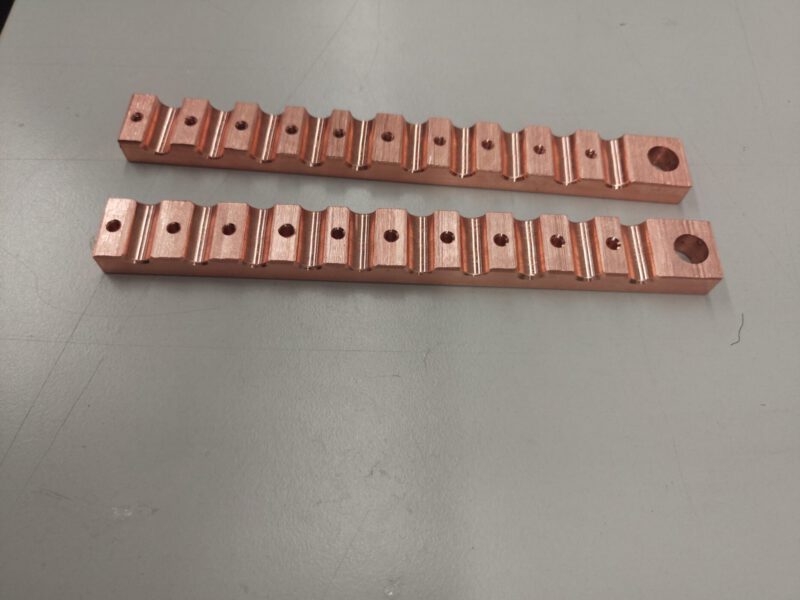
The first prototype was built within weeks, using simple tools: a block of copper, carbon rods, GFRP rods for stability and just a handsaw and drill.
Initial results:
Heat transfer to clamps was drastically reduced.
The size of the assembly could be made much smaller.
Abuse tests were promising: even after soaking the rods in water for days and then running currents up to 1000 A through one rod, the system continued to work without failure.
The main drawbacks appeared later:
Carbon is brittle. Dropping a hammer or stepping on the resistor would break it. This doesn’t happen under normal use, but accidents do happen…
Since i just joined team Foo occasionally, i was able to compare their winches better with my setup. Unfortunately, performance wasn’t even close with their setup. The hoped for benefit due to the negative temperature gradient can’t be so big.
Refining the Design
Through several iterations, I arrived at a much simpler and more robust concept:
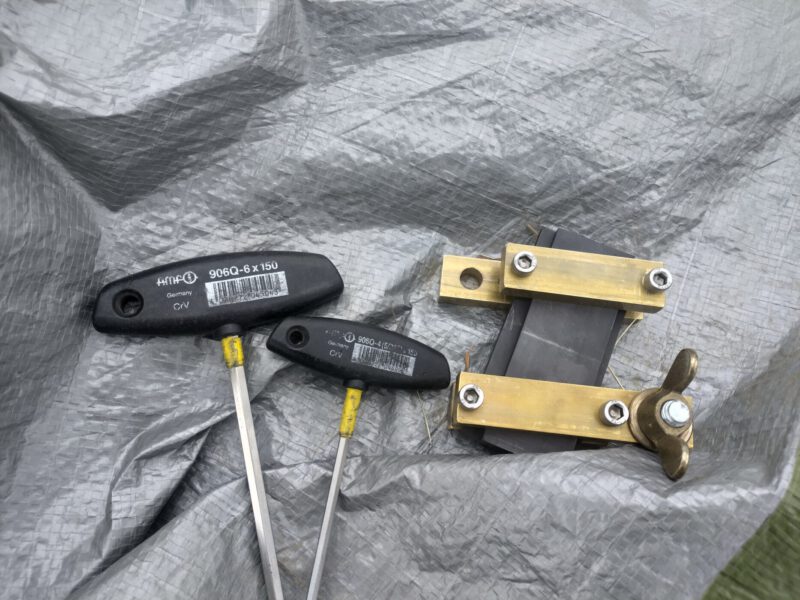
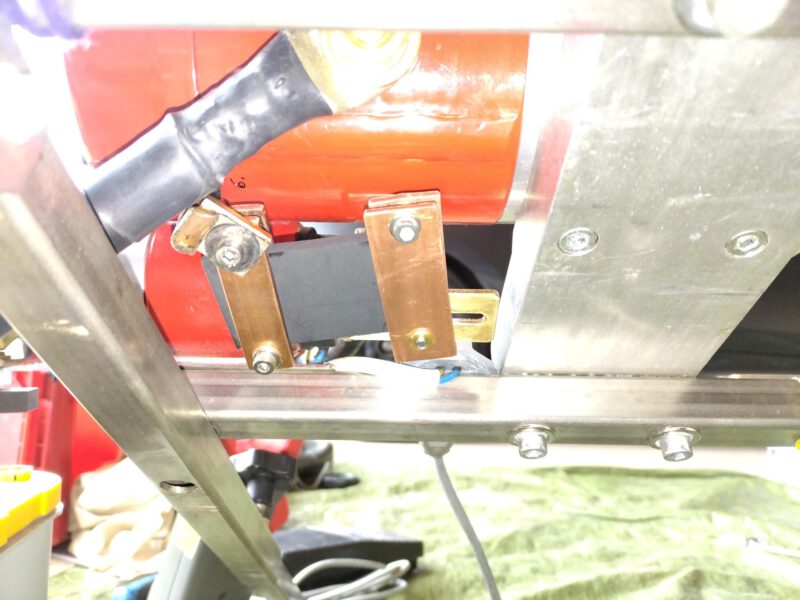
Small carbon plates pressed directly onto conductors
Compact enough to be fixed on the winch itself (safer than on the battery)
Easy to protect with covers or under the winch
Simple to build with basic tools (saw, drill, thread cutter, no CNC)
This design is:
Safe – no exposed hot parts near the battery
Robust – less prone to damage from accidents and regular use
Less heat – much less heat in clamps and cables
Accessible – buildable in under two hours without special equipment
Measurements and Performance
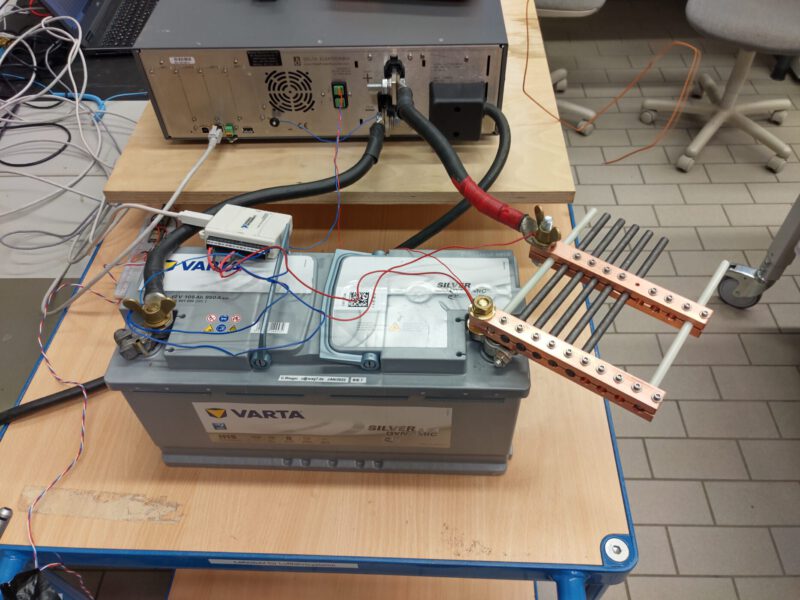
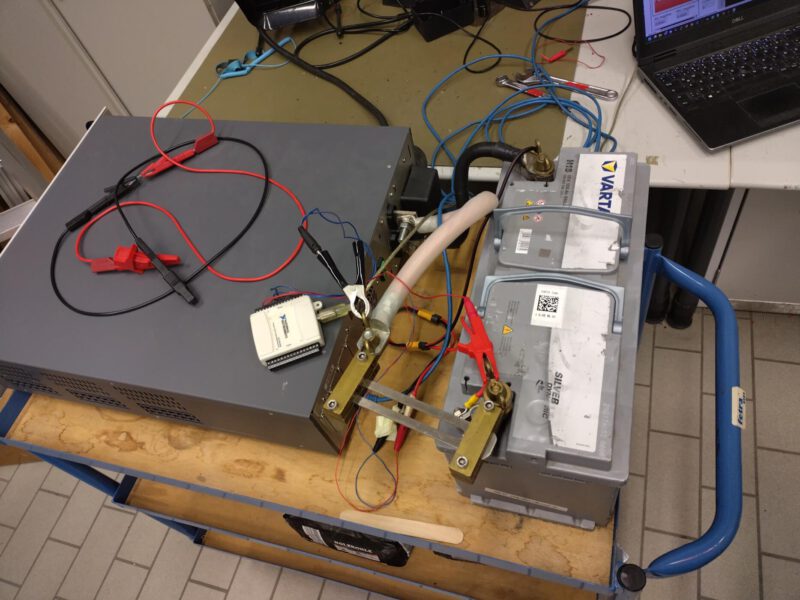
To quantify the negative temperature coefficient effect precisely for this report, I compared stainless steel and carbon resistors in September 2025 using an electronic load with my large Varta AGM battery.
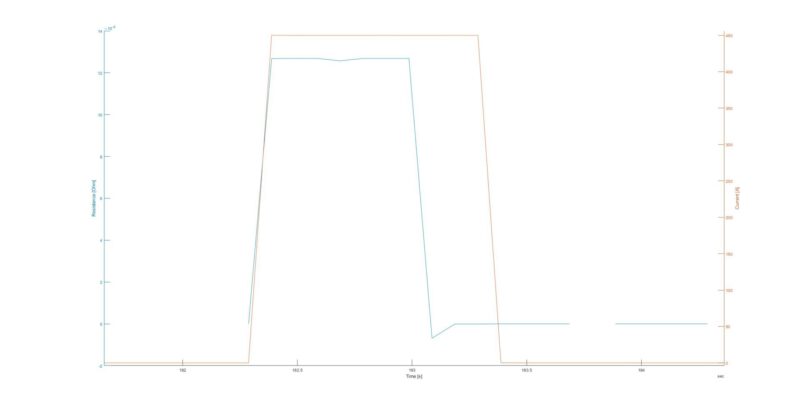
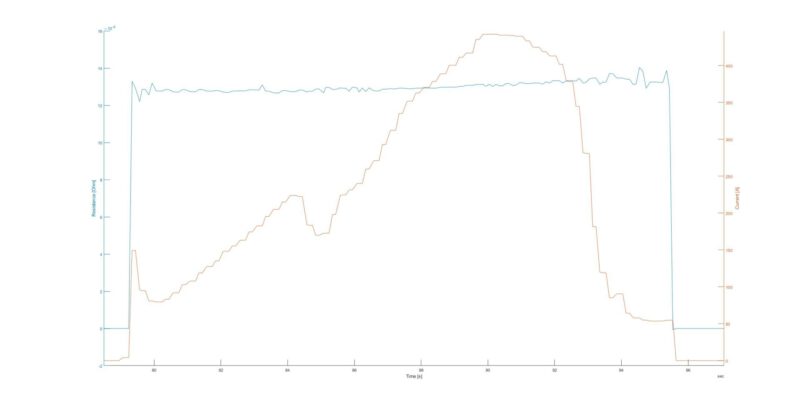
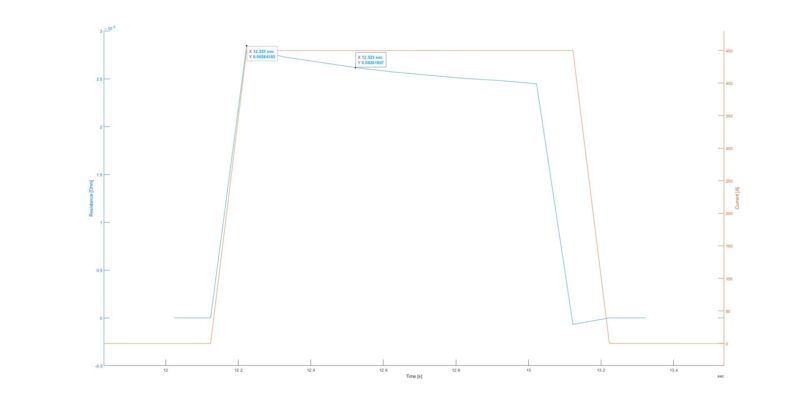
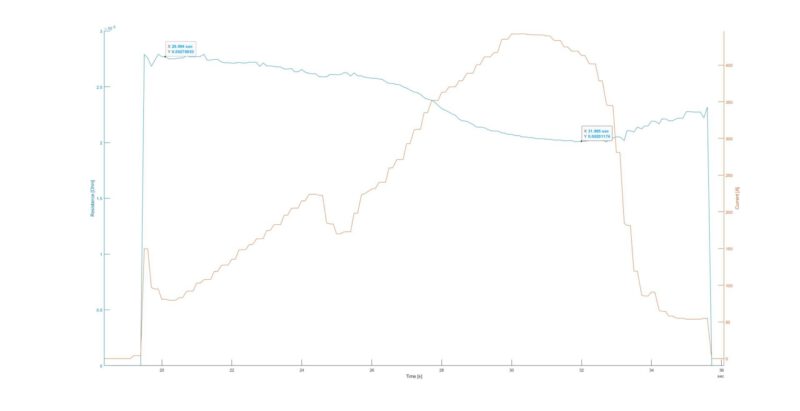
One 1second, 450A impulse simulates the measuring of the winch system. (The winch is blocked and 300ms after the current starts, the current measurement is performed) The current is a bit too low The simulated launch uses a current profile measured by MCM München in one of their older Magazines. I think it was 2007, when they did these winch measurements. I used the one with high current going over 440A, representing an extreme scenario that for sure represents too much current.
Stainless Steel Resistor
Length: 114 mm (≈ 1.2 mΩ)
Under 450 A impulse: nearly constant resistance (1.28 → 1.28 mΩ)
Under simulated launch: resistance rose slightly (1.28 → 1.34 mΩ)
Carbon Resistor
Dimensions: 5 × 8 × 14 mm block (≈ 2.8 mΩ)
Under 450 A impulse: resistance dropped (2.84 → 2.62 mΩ in 300 ms)
But you have to reduce this by at least the reduced resistance at impulse load -> max 0.54mOhm reduction without including increasing resistance of cables, motor,…
Key Takeaway: Carbon resistors do show a measurable drop in resistance under load, but the effect is modest. During the first half of a launch, this is even slightly negative: Effectively increasing your resistance. Setting the correct resistance precisely is also trickier, since small adjustments in length produce large changes. This means that you must stay a little bit further away from the limit to be safe.
Lessons Learned
After hundreds of launches, oscilloscope measurements in the field, and years of refinement, I can conclude:
Carbon resistors are safe, robust, reliable, and cheap to build.
They solve the heat and safety issues of stainless steel.
They make AGM batteries easier to use. Therefore providing extra safety against overpowering batteries and during transport
The performance effect is small compared to the bigger factors: battery quality, motor selection, and—most importantly—training.
For me, the real value of these resistors was not about gaining a competitive edge, but about the process: experimenting, solving problems, and learning a great deal about how winch systems behave.
In practice, their advantage is clear—they reduce heat, are inexpensive to build, and make the winch setup easier and safer to use. The real performance gains still come from training and choosing the right motor and battery, but carbon resistors make the whole system more accessible and reliable for everyone.